Master MCAT kinematics concepts including velocity, acceleration, displacement, projectile motion, and free fall equations. Includes practice questions with detailed answers.

(Note: This guide is part of our MCAT Physics series.)
Part 1: Introduction to kinematics
Part 2: Displacement, velocity, and acceleration
a) Defining the terms
b) Defining the sign conventions
c) Graphical interpretation
Part 3: Linear Motion with Constant Acceleration
a) Important formulas
b) How to problem solve
Part 4: Projectile Motion with Constant Acceleration
a) Important formulas
b) How to problem solve
Part 5: Circular Motion
a) Centripetal force and acceleration
Part 6: Inclined Planes
a) Gravity breakdown
Part 7: Torque
Part 8: High-Yield Terms and Equations
Part 9: Passage-Based Questions and Answers
Part 10: Standalone Questions and Answers
----
Part 1: Introduction to kinematics
Kinematics is the science of how objects move, and it's often the first module in an introductory physics class because it's such an everyday topic. Any student who's ever thrown something in the air will have at least some intuition about kinematics.
On the MCAT, kinematics is a medium-yield topic, and you'll only need to be familiar with it in a biological context. That said, kinematics is the physics topic most used in everyday life.
In the guide below, the most important terms are in bold font. When you see one, try to define it in your own words and use it to create your own examples. This is a great way to check your understanding, and phrasing terms in a way that makes the most sense to you and will make studying much easier (and much more effective!) in the long run.
At the end of this guide, there's an MCAT-style practice passage and standalone questions that will not only test your knowledge on forces, energy, and work but also show you how the AAMC likes to ask questions.
Receive Your Free MCAT Question of the Day
Get every last bit of practice in before test day with a free MCAT question delivered straight to your inbox daily.
----
Part 2: Displacement, velocity, and acceleration
Displacement, velocity, acceleration, and time are the main variables in kinematics. Most questions will give you information on some combination of these variables and ask you to solve for another. To do this, you’ll use the equations and definitions that relate each of them.
a) Defining the terms
First let’s define each term, starting with displacement. Displacement is a change in position, given as:
Δx = x − x0
where Δx = displacement,
x = final position,
x0 = the initial position
Displacement measures how far something moves and in what direction. It is usually given in a standard unit of meters (m). Displacement is often confused for distance, but they are not the same. Displacement needs to have both distance and direction. For example, “5 meters east” is a displacement, but “5 meters” is not.
Another way to think about this is that displacement only concerns the difference between the starting point and the final point. So, if you’re returning home after a cross-country road trip, your distance traveled might be thousands of miles, but your displacement will be zero because you ended in the same place that you started.
Velocity is a change in position over a change in time, expressed as:
v = Δx/Δt
where v = velocity,
Δx = x2 − x1 = displacement,
Δt = t2 − t1 = change in time
Velocity measures how fast and in what direction a position is changing. Its standard unit is meters per second (m/s). Similar to displacement and distance, velocity is often conflated with speed. Again, the difference is that velocity needs to specify a direction.
Velocity calculated using the above equation is usually the average velocity, or a calculated average of all velocities over a period of time. The period of time may be as short as seconds or milliseconds.
In contrast, instantaneous velocity refers to velocity that is measured at a single moment in time. Instantaneous velocity cannot be measured and must be calculated using derivatives and integrals. Since calculus is not tested on the MCAT, instantaneous velocity is out of the scope of the exam. However, average velocity is still fair game—and you may be asked to calculate velocity using a table of values.
a = Δv/Δt
where a = acceleration,
Δv = v2 − v1 = change in velocity,
Δt = t2 − t1 = change in time
Just like the previous two terms, acceleration measures the magnitude of the change as well as its direction. Its standard unit is meters per second squared (m/s²). Note: even if a velocity remains at the same magnitude for an object, there can be an acceleration if the object is changing direction.
You might have noticed how much we emphasized direction in each of those definitions. We included direction because displacement, velocity, acceleration are all vectors, meaning they have magnitude and direction. Each must have both! A good way to think about vectors is by imagining them as arrows. An arrow has to have some length, and it has to point in some direction (otherwise, it’s not an arrow!)

Figure 1 Vector addition

Vectors can also be combined. Consecutive displacements in the same direction, for example, will make a bigger displacement, and displacements in opposite directions will cancel out (as shown on the right side of Figure 1).
b) Defining the sign conventions
Most kinematics problems exist in one or two dimensions. It is usually most convenient to use a vertical y-axis and a horizontal x-axis to define direction. Convention defines up and right as positive, while down and left are negative.
So, if someone walks 10 meters to the right, we say Δx=+10 m. Similarly, if someone walks 10 meters to the left in 10 seconds, v= -1 m/s.
c) Graphical interpretation
The ability to interpret graphs of displacement, velocity, and acceleration versus time is an important skill in introductory physics. In addition to basic graph interpretation skills, there are a couple of relationships specific to kinematics graphs.
First, consider the slope of a displacement-vs-time graph. Slope is defined as rise over run, or the change in the vertical axis over the change in the horizontal axis.

Figure 2 The slope of a displacement vs. time graph
In this case, then, the slope equals Δx/Δt. You might recognize that equation, too—it’s the definition of velocity! It turns out that the slope of a displacement-vs-time graph is velocity, and the slope of a velocity-vs-time graph is acceleration.
Next, consider a velocity-vs-time graph with just a constant velocity. What is the area under that line?

Figure 3 The area under the curve of a velocity vs. time graph
The shape is a rectangle, so its area is defined as width times height. In this case, width is the change in time and height is the constant velocity. Rearranging the velocity equation above tells us that this area must equal the displacement! In other words, the area under the curve on a velocity-vs-time graph is the displacement, and the area under the curve on an acceleration-vs-time graph is the change in velocity.
These relationships let you say a lot about the motion of an object even if you have one graph. Your tools in deciphering kinematics graphs are reiterated in the chart below.

Figure 4 Relating displacement, velocity, and acceleration
If you are familiar with calculus, it might help to know that velocity is the time derivative of displacement and that acceleration is the time derivative of velocity.
----
Part 3: Linear motion with constant acceleration
The simplest system in kinematics is an object moving strictly horizontally with constant acceleration, like a car speeding slowing down as it approaches a red light or a car speeding up once the light turns green.
As a reminder, most problems of this type will give you information on some combination of displacement, velocity, acceleration, and time and ask you to solve for a missing variable. Now that we’ve defined each of the terms, let’s look at the equations that relate them.
a) Important formulas
If an object has a constant acceleration, we’ll use the following formulas:
v = v0 + at
Δx = ((v + v0)/2)t
Δx = v0t + (1/2)at2
v2 = v02 + 2aΔx
where Δx = displacement,
v = final velocity,
v0 = initial velocity,
a = acceleration
When using these equations, it’s important to remember to include negative signs, if necessary. (Remember: convention marks any Δx, v, or a pointing down or left as negative.)
b) How to problem solve
Constant acceleration kinematics problems in one dimension can be solved with the help of the equations introduced in the previous section. There are a few helpful steps for solving each problem if you see one on the MCAT.
Draw a picture. This helps you understand what’s really going on.
Write down all the information given to you (and label it in your picture).
Identify what you need to solve for.
Solve. There are two ways to do this:
a) Use the equations. This is what you’ll do most of the time. Try to find the equation that has one variable you need to solve for and other variables that you know. If no equation immediately satisfies this, find equations that contain all variables that you know, except for one. Often, solving for more variables—even if they aren’t the ones you are initially asked to solve—will help you.

Figure 5 Deciding the right equation to use
b) Graph it. If you have enough information to make a graph of Δx, v, or a versus time, that may end up being the simplest way to solve your problem. If this is the case, you’ll use slope and area under the curve.
----
Part 4: Projectile motion with constant acceleration
Projectile motion is the two-dimensional motion of an object under the influence of gravity. Everything mentioned above still applies; now, you have an additional set of formulas for the y-direction. (This duplicate set of formulas is actually how you’ll solve any kinematics problem in two dimensions.)
a) Important formulas
vy = vy0 − 10t
Δy = vy0t − 5t2
Δx = vx0t
and sometimes,
vy2 = vy02 − 20Δy
b) How to problem solve
There are several facts about projectile motion that make solving problems easier.
X-velocity stays the same the whole time (because x-acceleration equals zero.)
At the peak of the object’s flight, its y-velocity equals zero.
If the ground is level, the flight is symmetric. The initial y-velocity will equal the final y-velocity, and the time from ground up to the peak of the flight equals the time from the peak back to the ground.
The most basic projectile motion problem gives you an initial x and y velocity and an initial height, and the question will ask you how far the object will travel horizontally.
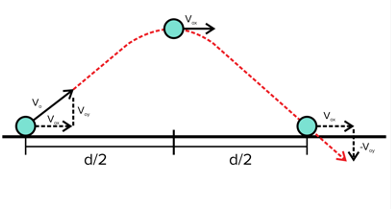
Figure 6 Projectile motion on a level surface. Since gravity is constant, you can find the amount of time and distance covered as a projectile returns to its original elevation by doubling the time and distance it takes for the projectile to reach its peak
Then, you plug the time you find into the third equation, and that’s it! Depending on the information given to you and what you’re being asked to solve for, the steps might change, but this logic stays the same.
Sometimes, you’ll be given the total initial velocity (v0) and the launch angle (θ). If this is the case, you use trigonometry to find vy0 and vx0. Specifically,
vy0 = v0sinθ
vx0 = v0cosθ
----
Part 5: Circular motion
Circular motion describes an object that is moving in a circle. A good visualization for circular motion is a ball on a string that you’re swinging above your head.
When an object is rotating in a circle, its displacement is the angle it has travelled. So, the original kinematics equations can be used if you substitute Δθ for Δx, ω for v, and α for a:
ω = ω0 + αt
Δθ = ((ω + ω0)/2)t
Δθ = ω0t + (1/2)αt2
ω2 = ω02 + 2αΔθ
where Δθ = angular displacement, or the change in angle of the object's location;
ω = angular velocity, or the change in angle over a change in time;
α = angular acceleration, or the change of angular velocity over a change in time
Other important concepts are period and frequency.
The period of motion is the amount of time it takes to complete one orbit.
The frequency of motion is how many orbits are completed in one second.
The equations are given by:
T = 2πR/vT
f = 1/T
where T = period,
f = frequency,
R = radius of the circle,
vT = tangential velocity
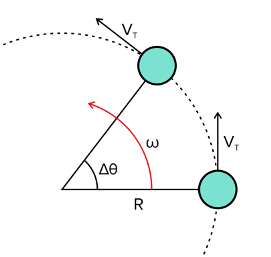
Figure 7 Circular motion and its key terms
a) Centripetal force and acceleration
When objects travel in circular motion, there is a centripetal force that pulls them toward the center of the circle. In the ball on a string visualization, the centripetal force is the tension in the string. There is also a special formula for the centripetal acceleration, or the linear acceleration that points towards the center of the circle. This concept is related to tangential velocity, or the linear velocity of the object moving in a circle. One way to understand tangential velocity is thinking of it as the velocity the ball on the string would travel with if you let go of it. The formula is:
ac = vT2/R
where ac = centripetal acceleration,
vT = tangential velocity,
R = the radius of the circular trajectory
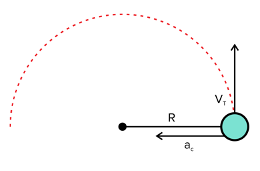
Figure 8 Centripetal acceleration and tangential velocity
----
Part 6: Inclined planes
Inclined planes change the direction of acceleration due to gravity. Instead of pointing straight down, the acceleration due to gravity will point parallel to the plane. For this reason, we’ll choose our directions to be parallel to the plane and perpendicular to the plane instead of horizontal and vertical.
In the parallel direction, for example, the equation:
v = v0 + at
becomes the following equation:
v|| = v||,0 + a||t
and the rest are adapted similarly!
a) Gravity breakdown
The equations work in exactly the same way; all you need to do is convert the vertical acceleration due to gravity to your new directions. Since the parallel direction isn’t perfectly vertical, the acceleration due to gravity in this direction will be slightly weaker. To find it, multiply -9.8 by the sine of the angle of the incline.
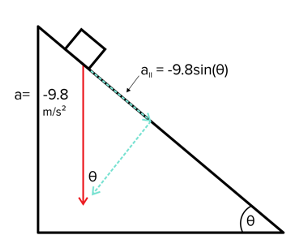
Figure 9 How to calculate acceleration due to gravity on an inclined plane. In the y-direction, multiply the acceleration by sin of the angle of the plane. In the x-direction, multiply the acceleration by the cos of the angle of the plane
So,
Once you complete that conversion, any kinematics problem on an inclined plane behaves just like a problem on a flat surface!
----
Part 7: Torque
Torque causes angular acceleration. It is a force applied to an object that pivots around a point. You apply torque to doors, for example, when you swing them open. Torque is defined by:
T = R × F × sinθ
where T = torque,
R = perpendicular distance from pivot to application point, also known as moment arm,
F = the force applied,
θ = the angle between the vectors of R and F
Notice that torque is highest when R and F are perpendicular, and torque is zero when they are parallel. This is why you push on the face of a door rather than pulling it directly out of the hinges.
To obtain angular acceleration from torque, use
T = I × α
where α = angular acceleration,
I = moment of inertia (a given value)
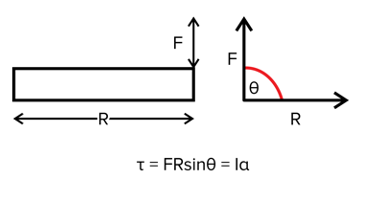
Figure 10 Torque
----
Part 8: Kinematics equations and high-yield terms
Displacement: a change in position, written as Δx
Velocity: a change in position over a change in time, written v=Δx/Δt
Acceleration: a change in velocity over a change in time, written a = Δv/Δt
Vector: a quantity that has both magnitude and direction
Projectile motion: the two-dimensional motion of something under the influence of gravity
Acceleration due to gravity: the vertical acceleration felt by objects on earth. Equals -9.8 m/s2
Circular motion: the motion of an object that is moving in a circle
Angular displacement: the change in angle of an object’s location, written Δθ
Angular velocity: the rate of change of angular displacement, written ω=Δθ/Δt
Angular acceleration: the change of angular velocity over a change in time, written α=Δω/Δt
Period: the amount of time it takes for an object in circular motion to complete one orbit
Frequency: the number of orbits completed in one second by an object in circular motion
Centripetal acceleration: the linear acceleration that points towards the center of the circle
Tangential velocity: the linear velocity of the object moving in a circle
Inclined planes: a slope that changes the direction of the acceleration due to gravity
Torque: a force applied to an object that pivots around a point; causes angular acceleration
Linear velocity
v = Δx/Δt
Linear acceleration
a = Δv/Δt
Under constant acceleration
v = v0 + at
Δx = ((v + v0)/2)t
Δx = v0t + (1/2)at2
v2 = v02 + 2aΔx
Projectile motion, assuming g ≈ 10 m/s2
vy = vy0 − 10t
Δy = vy0t − 5t2
Δx = vx0t
Period of circular motion
T = 2πR/vT
Frequency of circular motion
f = 1/T
Converting angular motion to linear motion
Δx = Δθ × R
vt = ω × R
*Note that θ must be in radians
Centripetal acceleration
ac = vT2/R = Rω2
Torque
T = R × F × sinθ = I × α
----
Part 9: Kinematics practice passage
Researchers are studying how waste is eliminated from cells, and they have identified a novel enzyme that aids in the degradation of cellular waste products. The enzyme is bound to an organelle before it is released into the cytoplasm. Prior to being released, the enzyme propels itself through an ATPase in a circular path around the organelle.
Researchers study this system in several different kinds of cells to gain insight into the efficiency of the waste removal by studying selective protein degradation of unfolded proteins. In previous experiments, researchers determined that the tension in each bond is the same, meaning that in each system, the centripetal acceleration is the same and given by: ac=vT2/R=Rω2
Though the bond tension is the same, the researchers hypothesize that the length of the bond is different in each cell type. Researchers are unable to directly measure the lengths of the bonds. However, an ATP is cleaved every time the enzyme passes its starting position. The researchers are able to count how many inorganic phosphates are generated per second. The results for four different systems are shown in Table 1.
Table 1 ATP cleaved per second by cell type
| Cell type | ATP cleaved per second |
|---|---|
When the organelle detects nearby waste via a second protein, the enzyme is released. The enzyme travels at a constant negative acceleration due to the viscosity of the cytoplasm. The researchers want to use these results to calculate the average distance from the released enzyme to the waste. The motion of the enzyme is given by:
Δx = v0t − (1/2)at2
(Note: The information in this passage was created for the sole purpose of presenting an MCAT-style passage and should not be construed to be factually true.)
Question 1: In which system is the period of the enzyme’s movement the largest, and what is the value of that period of motion?
A) System C; 2 seconds.
B) System C; 0.5 seconds
C) System D; 10 seconds
D) System D; 0.1 seconds
Question 2: In terms of period, T, and the unknown value R, what is the tangential velocity of the enzymes when they are bound to the organelle?
A) vT = R/(2πT)
B) vT = 2πTR
C) vT = (2πR) / T
D) vT = 1 / (2πTR)
A) VT = (acT)/2π
B) VT = (acT)/2π
C) VT = 2π/(acT)
D) VT = 2π/(acT)
Question 4: If an unfolded protein is the same distance from the enzyme in each system, and in all cell lines the enzyme reaches the unfolded protein, in which system will unfolded protein be removed the quickest?
A) System A
B) System B
C) System C
D) System D
Question 5: If the tangential velocity in one of these systems is 3 x 10⁻⁶ m/s, and the distance from the release point to the waste is 0.06 x 10⁻⁶ m, how long will it take for the waste to be removed, ignoring the viscosity of the fluid?
A) 2 seconds
B) 0.02 second
C) 0.12 seconds
D) 12 seconds
Answer key for kinematics practice passage
1. Answer choice B is correct. The number of ATP cleaved per second corresponds to the number of complete cycles per second, according to the passage. For this reason, those numbers are also the frequencies of motion. We know that the period of motion is the reciprocal of the frequency, so the system with the lowest frequency will also have the largest period (choices C and D are incorrect). System C has the lowest frequency, and the reciprocal of 2 per second is 0.5 seconds (choice A is incorrect; choice B is correct).
2. Answer choice C is correct. The equation for period is:
T = 2πR/v
Once this equation is rearranged and solved for velocity, we obtain:
v = 2πR/T
(choice C is correct; choices A, B, and D are incorrect). Another way to think about this is that linear velocity is defined as the displacement over time. The displacement is one circumference of the circle (= 2πR), and the time is one period.
3. Answer choice A is correct. There is no equation that directly relates a and T to tangential velocity. However, there are equations that relate a and T separately to each tangential velocity and radius. We know:
a = v2/R, T = 2πR/v
Use the first equation to solve for R:
R = v2/a
We can use this result in the second equation to obtain:
T = (2π/v) × (v2/a) = 2πv/a
Finally, we use this result to solve for our variable of interest, v:
v = Ta/(2π)
(choices C and D are incorrect).
4. Answer choice D is correct. We know that in each cell line the enzyme will travel under the same constant acceleration to the location of the waste (or unfolded protein in this case). Since the enzymes all have the same acceleration, the enzyme with the highest initial velocity will reach the unfolded protein the fastest. We also know that the initial velocity will be the same as the tangential velocity when the enzyme was spinning. Since system D has the highest tangential velocity, it will remove the waste the quickest (choice D is correct; choices A, B, and C are incorrect).
5. Answer choice B is correct. We are told to ignore the viscosity of the fluid, so we can set the acceleration equal to zero. Then, the equation of motion simplifies to x=vt and t=x/v. We know x is 0.06 x 10⁻⁶ m and v is 3 x 10⁻⁶ m/s. Dividing x by v, we get t = .02 s (Answer choice B is correct).
----
Part 10: Kinematics standalone practice questions
Question 1: If a protein moving 30 mm/s begins to slow down at a rate of 5 mm/s², how far will it travel before it stops?
A) 6 mm
B) 0 mm
C) 180 mm
D) 90 mm
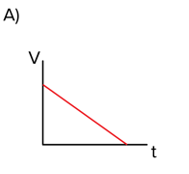
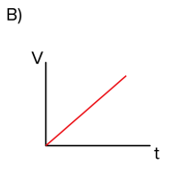
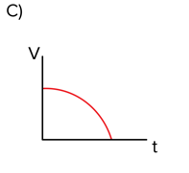
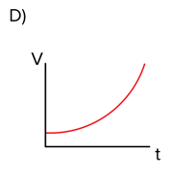
Question 2: Which of the following graphs shows the velocity of an object subject to a constant negative acceleration?
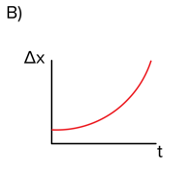
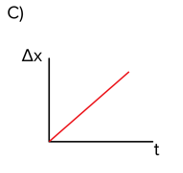
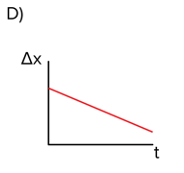
Question 3: Which of the following graphs shows the motion of an object subject to a constant positive acceleration?
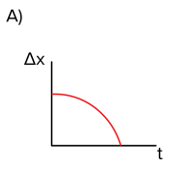
Answer key for kinematics practice problems (standalone)
1. Answer choice D is correct. First, we calculate the time it takes for the protein to stop moving. By using the equation for velocity under constant acceleration and plugging in known values, we can obtain: v = v0 − a × t → 0 = 30 − 5t Solving for t gives us 6 seconds. We can use this value in the equation for projectile motion: x = v0t + (1/2)at2 → x = v0 × 6 + (1/2) × 5 × 36 After simplifying, x = 180 − (1/2) × 180 = 90 mm (answer choice D is correct).
2. Answer choice A is correct. We know that the slope of a velocity versus time graph is the acceleration. Because we know acceleration is constant, we know the velocity has to be a straight line (choices C and D are incorrect). Since the acceleration is negative, the slope also has to be negative (choice B is incorrect; choice A is correct).
3. Answer choice B is correct. We know that the slope of a displacement versus time graph is the velocity, and the slope of a velocity versus time graph is the acceleration. The first step is finding what a graph of the velocity will be. Since acceleration is constant and positive, the velocity must be a straight line with a positive slope. Now, we match that velocity with the displacement graphs. We know that velocity changes, so the graph of displacement is not a straight line (choices C and D are incorrect). We also know the velocity starts low and ends high, so the slope of displacement at the beginning must be less steep than the slope at the end (choice A is incorrect; choice B is correct).
Not ready to commit to your MCAT prep at this time?
Enter your name and email for a free MCAT question delivered straight to your inbox daily.